

Action-conditioned world models, predictive representations and planning.
勘境 / KineJing 研究动作条件世界模型、预测表征与规划,公开可复用的工程改进、选定实验结果和复算数据。公司法定主体为 合肥勘境智能科技有限公司;核心研究实现保持私有。
We study how predictive representations can support planning. Our public work includes maintained research extensions, engineering fixes and selected experimental evidence. Each result is tied to its protocol and original sources.
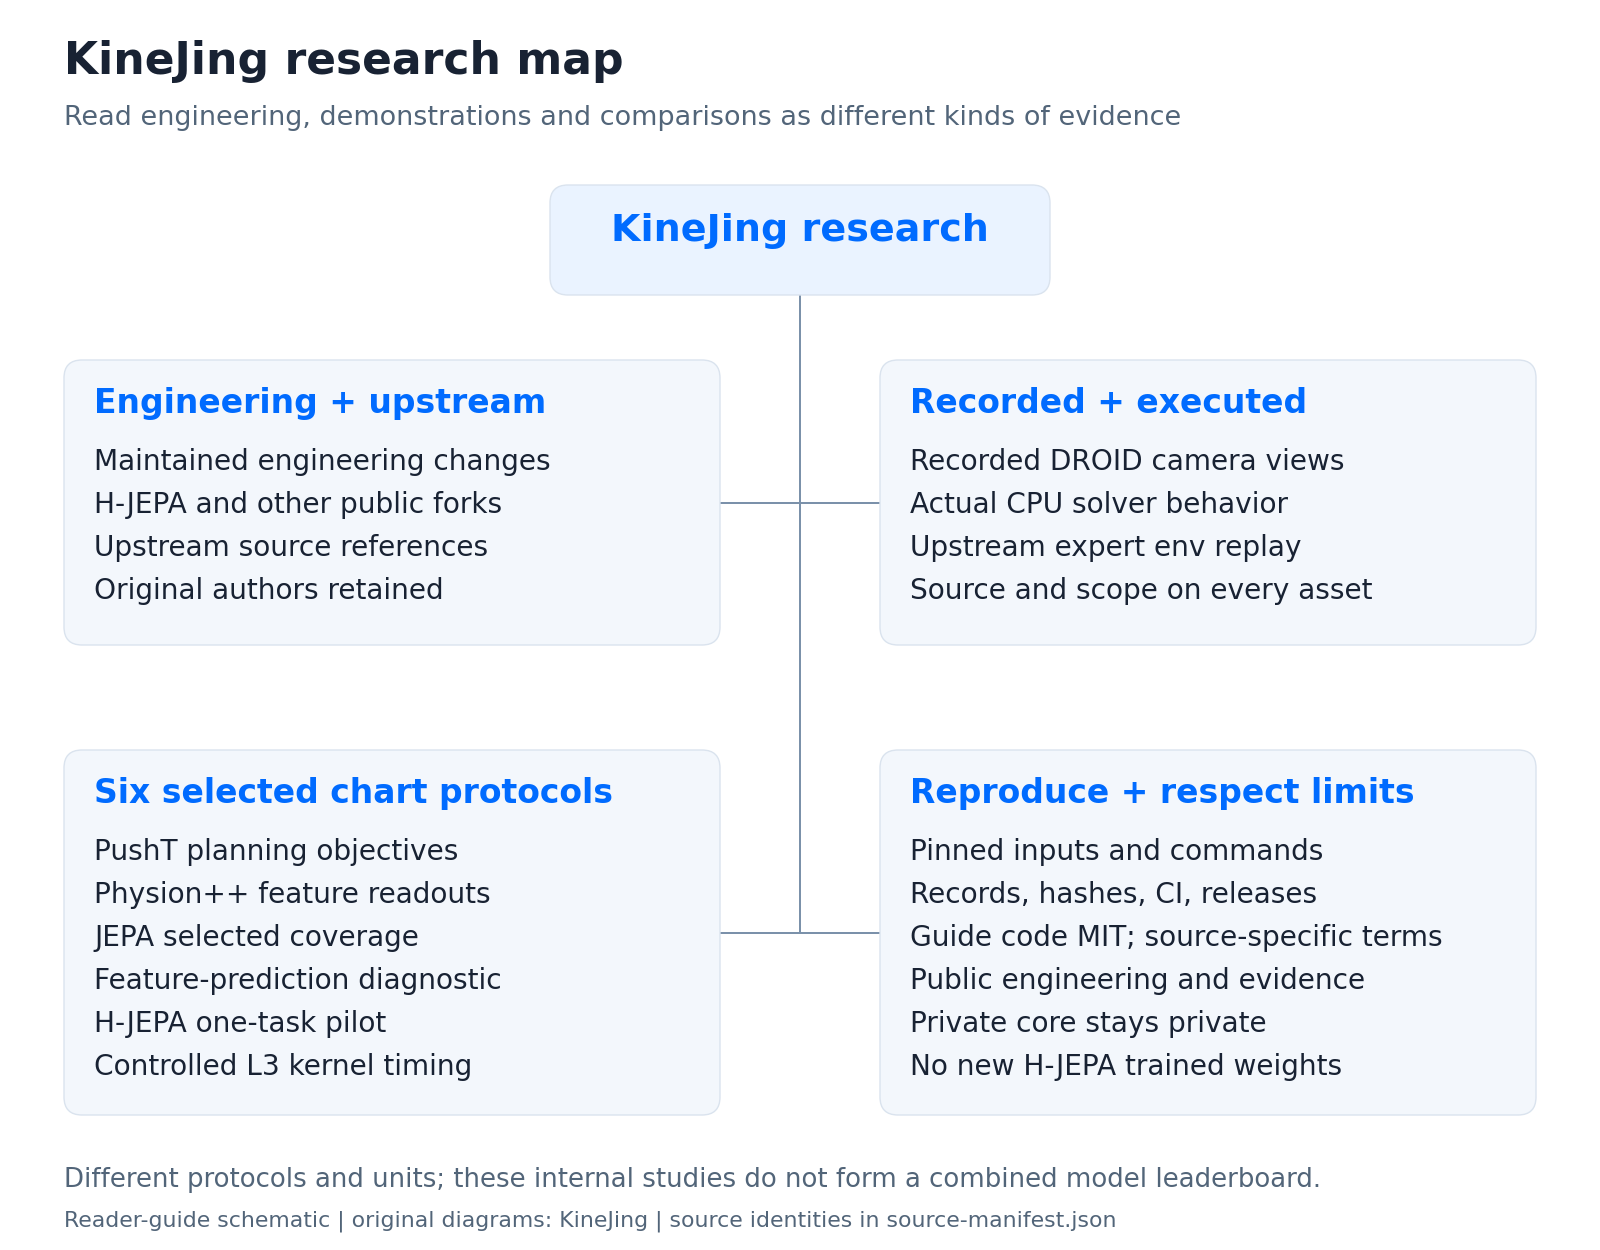
Reader guides · 研究导览示意: Research map · 研究目录 · H-JEPA options · 规划工程选项 · Evidence chain · 证据发布链 · English / 中文 Mermaid sources. These are authored guides, rather than experimental outcomes.


Research hub · 研究索引 · H-JEPA extension · Evidence & protocols · 结果与条件 · Media gallery · 实录与重放 · Figures · 对比图 · Release v0.2.0 · Website · 官网
| Recorded or executed | Scope and reproduction |
|---|---|
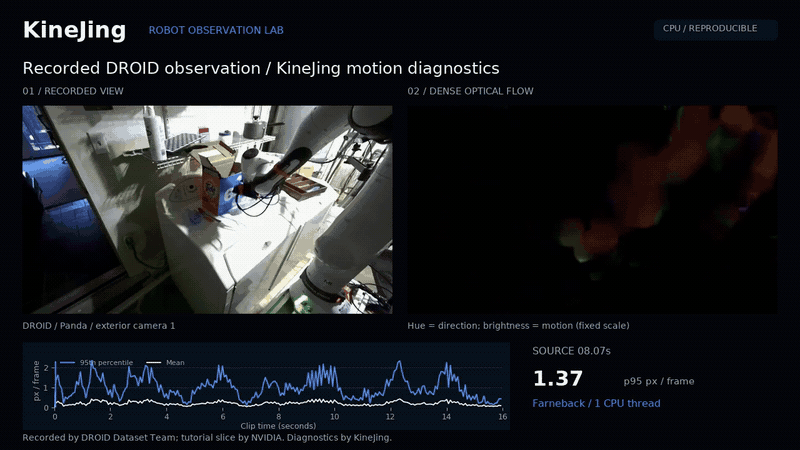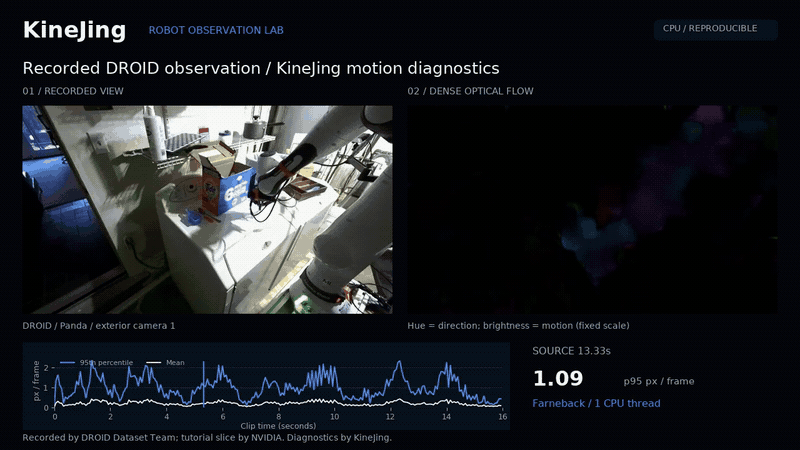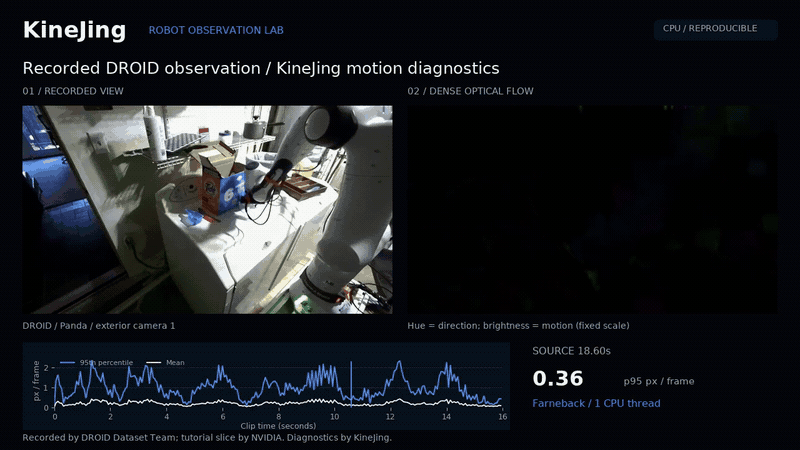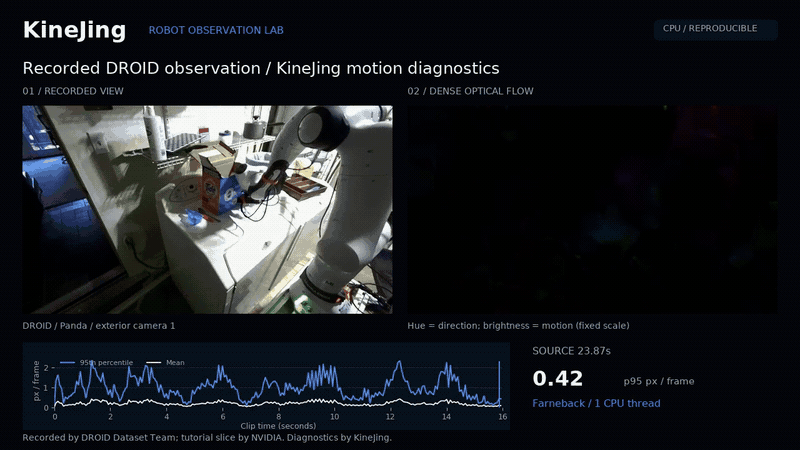 |
Recorded robot observation + CPU motion diagnostics. DROID Dataset Team footage, supplied by NVIDIA Cosmos; KineJing computes Farneback optical flow over 240 recorded frames. Recorded footage with CPU motion analysis; the scope is observational. Reproduce · Source & OpenMDW-1.1 terms · Execution record |
 |
Actual H-JEPA GradientSolver on CPU. The same four evaluations on the toy objective (a - 1)^2: default returns recorded cost 64; opt-in retention returns 1. A controlled illustration of the upstream solver and KineJing's optional plan retention. Reproduce & original authors · Actual calls & source identity |
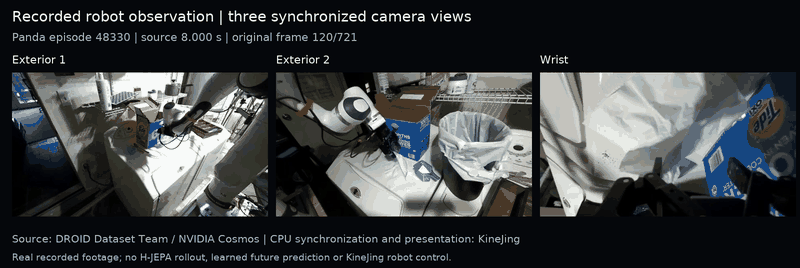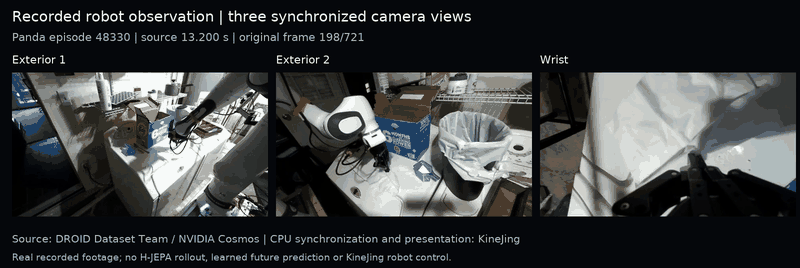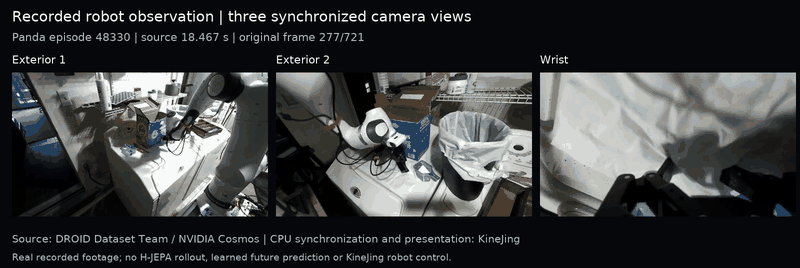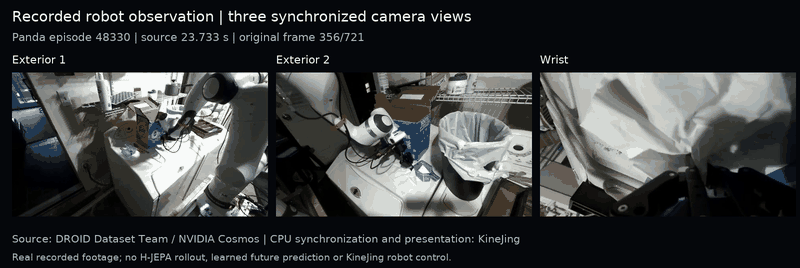 |
Three-camera recorded observation. Exterior 1, exterior 2 and wrist views from the same DROID/NVIDIA episode: 240 frames per camera over 16 seconds. KineJing provides CPU frame checks and visualization for the recorded views. Reproduce · Attribution & OpenMDW-1.1 · Frame audit |
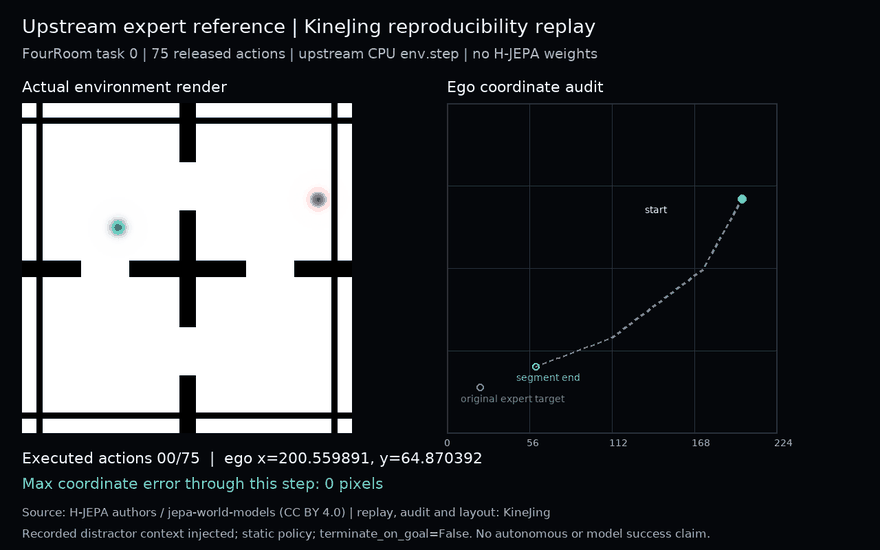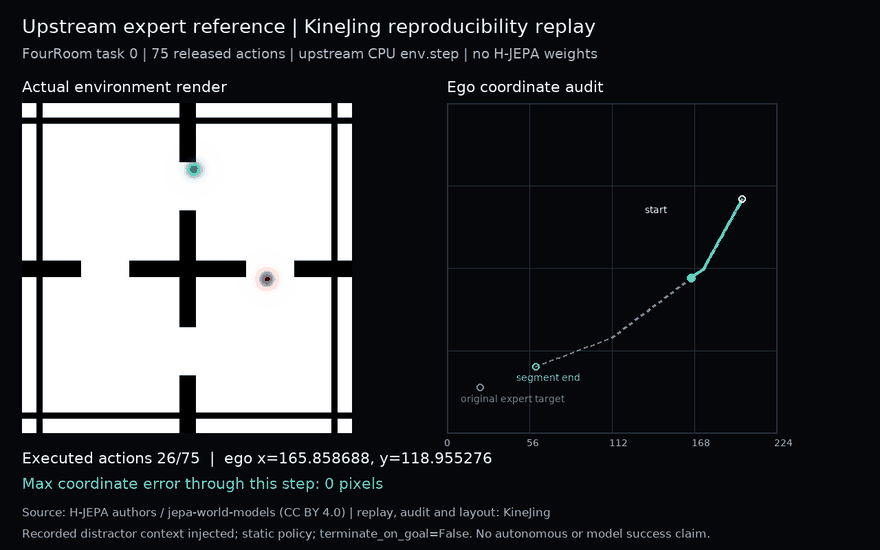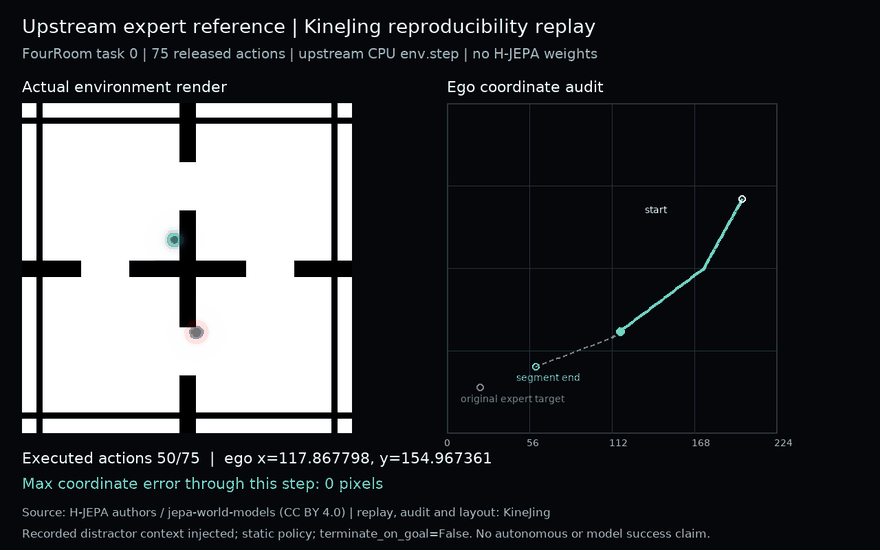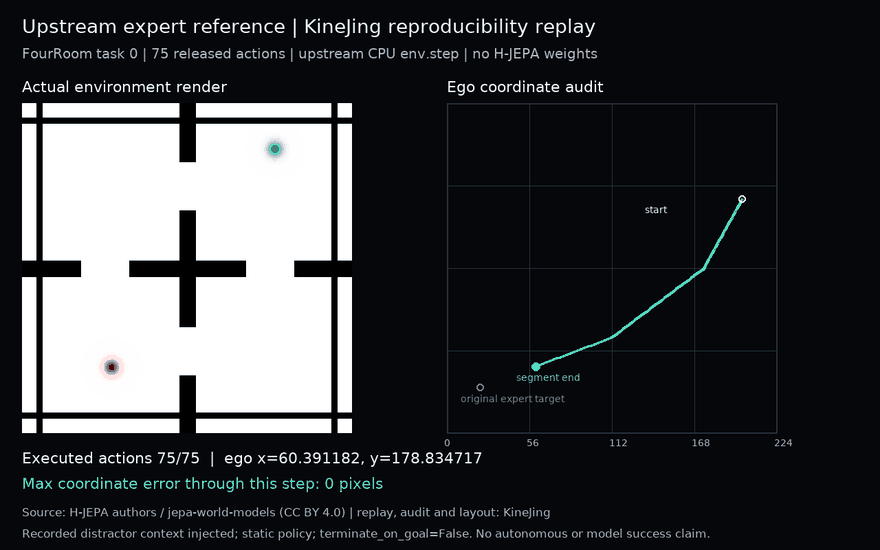 |
Upstream expert reference, actual CPU replay. 75 released actions execute through the official FourRoom environment; all 76 ego positions match the released segment. Recorded distractor context is injected, its policy is static, and goal termination is disabled. An audit of upstream expert trajectories replayed by KineJing, focused on execution and coordinates. Reproduce · Attribution & media CC BY 4.0 · Coordinate audit |
Media provenance, licences and checksums accompany every example. Upstream research demos elsewhere retain the original authors' attribution.
An engineering extension of H-JEPA, by Wancong Zhang, Basile Terver, Mike Rabbat, Yann LeCun and Randall Balestriero. The original implementation, model weights, paper results and MIT license retain their upstream attribution.
| KineJing contribution | Inspect or reproduce |
|---|---|
| Retain the best finite, feasible evaluated GD trajectory per environment; opt-in and disabled by default | Upstream PR #9 · Behavioral regressions |
| Compute gradients for candidate actions without accumulating unused model-parameter gradients; opt-in | Changes and switches |
| Run fixed-checkpoint paired evaluations with recorded task seeds, configuration and asset identities | Evaluation entry point · Published pilot evidence |
Verification, 2026-10-11: CPU CI reports 134 passed, 1 skipped. The upstream PR is open, not merged. The one-task integration pilot succeeded in both arms; the candidate used six more environment steps. The frozen 300-episode comparison is ongoing.
这些检查证明特定工程行为;单任务 pilot 没有成功率提升证据。我们尚未据此发布新训练模型或证明全面超越上游。
| Entry | What you can inspect |
|---|---|
| kinejing-research | Public research index, reproduction entry points and evidence navigation |
| H-JEPA-KineJing | Opt-in planner/runtime changes, tests and fixed-checkpoint evaluation tools |
| Open-source engineering directory | Seven other maintained adaptations, their original projects, licenses and test paths |
| Published evidence | Protocols, individual outcomes and explicit limits for selected internal results |
Other public forks are upstream source references unless their KineJing maintenance note identifies a tested change. Upstream demonstration videos remain the original authors' work.
Public/private scope · 公开与闭源范围 explains the published code, evidence and demonstrations, and the core implementation that remains private.
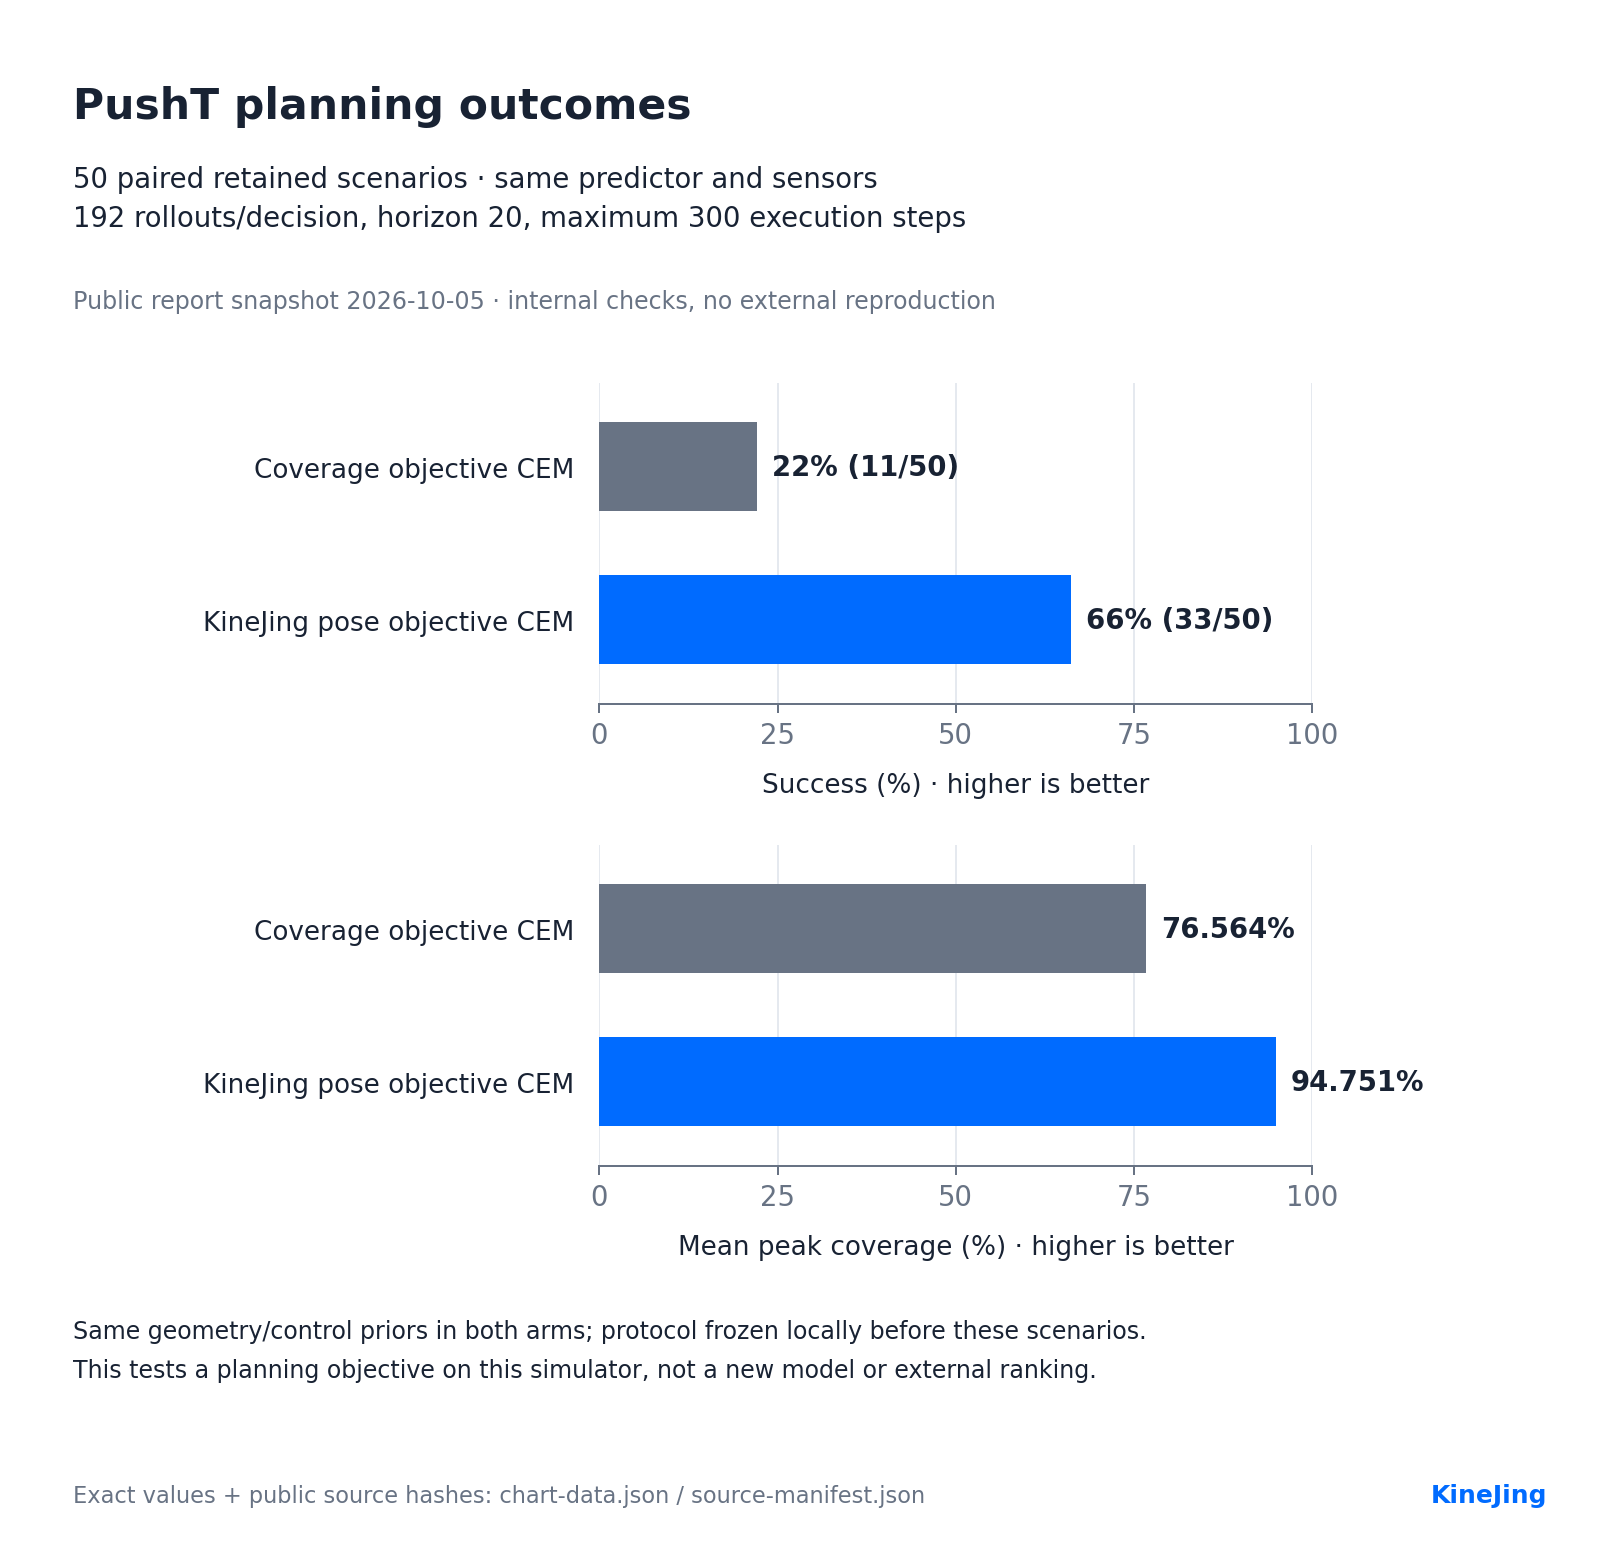
PushT: 33/50 vs 11/50 successful scenarios. Same predictor, sensors and per-decision rollout budget; this compares planning objectives on this simulator. 同一协议下的规划目标对照,不是通用模型排名。
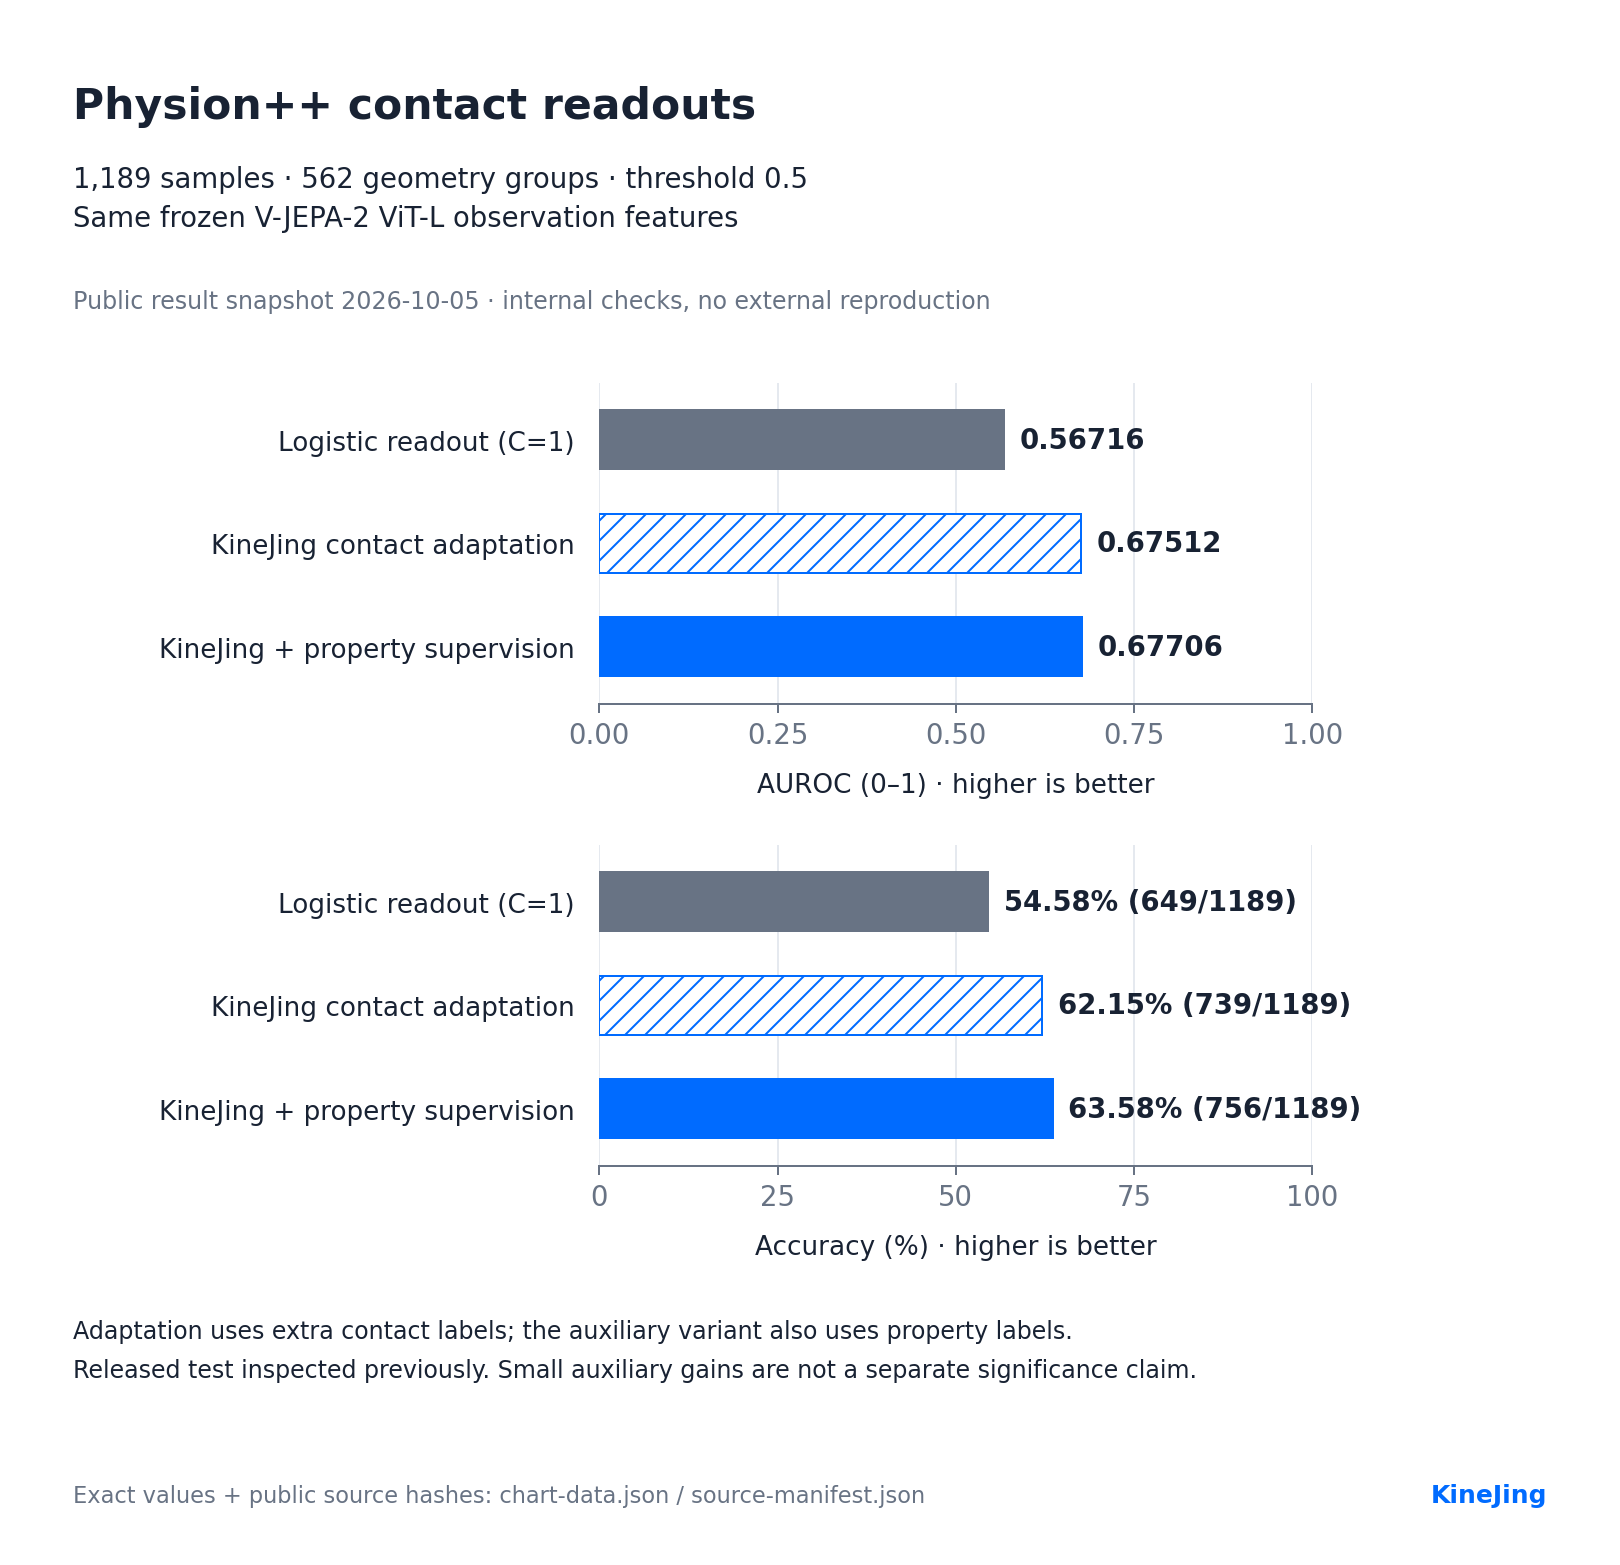
Physion++: 1,189 samples / 562 geometry groups. The task adaptations add training supervision to the same frozen V-JEPA-2 features; this is a previously inspected released-test re-evaluation. 相同表征上的任务读出对照,额外训练监督与测试复评条件随图公开。
Six selected comparisons · 六项精选对比与条件 · Chart inputs & reproduction · Controlled kernel timing sources
| 对比 | 勘境方案 vs 对照 | 评测范围 |
|---|---|---|
| PushT 规划成功率 ↑ | 66% vs 22%,+44 个百分点 | 50 对模拟场景,同预测器与决策预算 |
| JEPA-WM + 本地读出头:位置误差 ↓ | 1.364 vs 37.983 / 39.275 / 37.696 px | 固定开发动作集合,勘境方案额外使用物理先验 |
| V-JEPA-2 表征接触预测:AUROC ↑ | 0.677 vs 0.567 | Physion++ 1,189 样本复评,额外训练监督 |
| KineJing 特征预测误差 ↓ | 降低 15.75%,对照首帧保持 | 10 个本地评估回合,单种子、已探索开发样本 |
| CNN 前端一步位置误差 ↓ | 降低 22.48%,对照颜色特征 | 50 个测试场景,同动力学、模拟器监督 |
内部实验,尚无独立外部复现。各项条件不同,结论限定于对应任务与协议。
全部对比、评测条件与可复算数据 · PushT: 50 paired outcomes · Physion++: labels and predictions
2026-10-11 · KineJing's local paired MuJoCo / Franka Panda pushing experiments.
| Metric | Baseline → optimized | Increase | Use / latency reduction |
|---|---|---|---|
| Dynamics fit sample efficiency | 6,000 → 1,500 transitions | +300.0% | −75.0% |
| Fit + validation sample efficiency | 7,200 → 2,700 transitions | +166.7% | −62.5% |
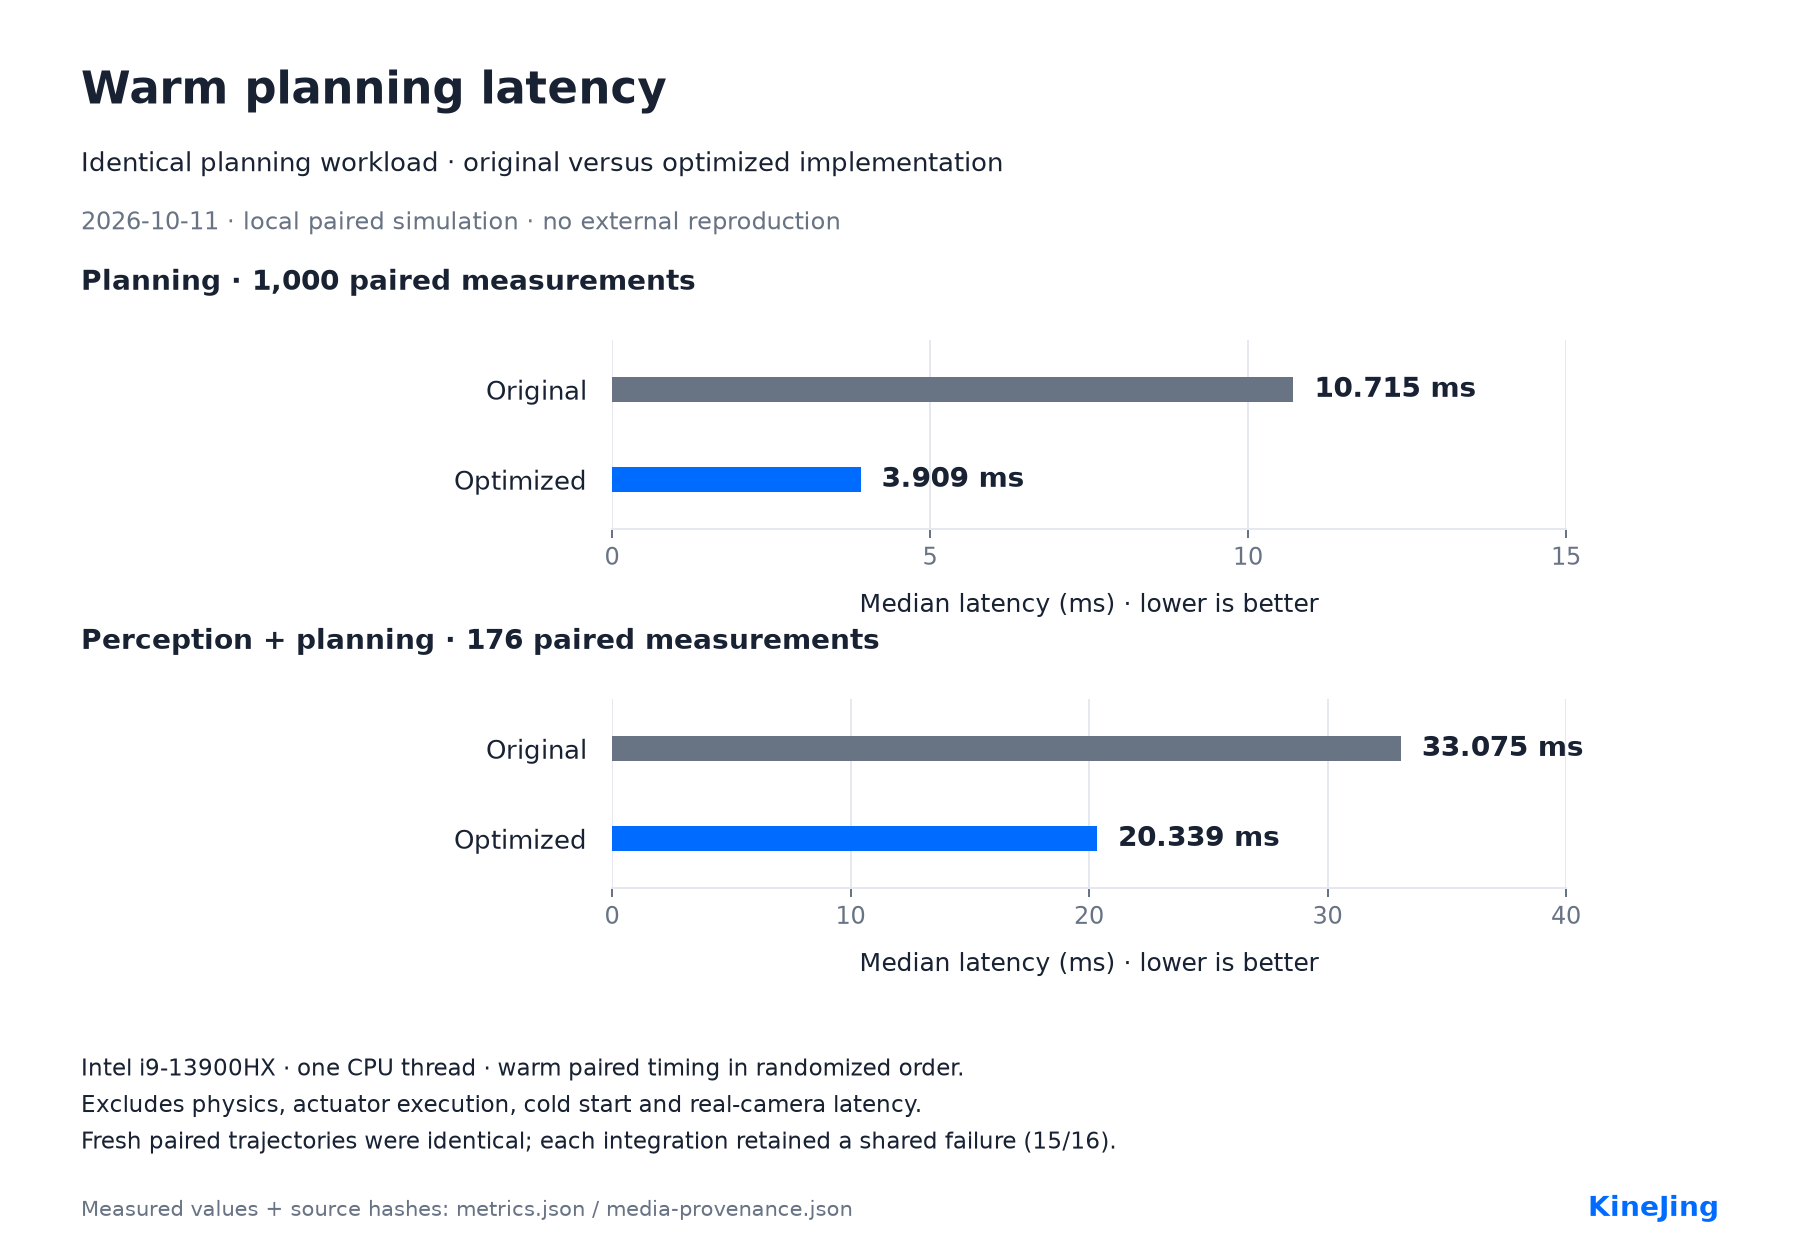
| Planning speed | 10.7145 → 3.9087 ms | +174.1% | −63.5% |
| Perception + planning speed | 33.0751 → 20.3386 ms | +62.6% | −38.5% |
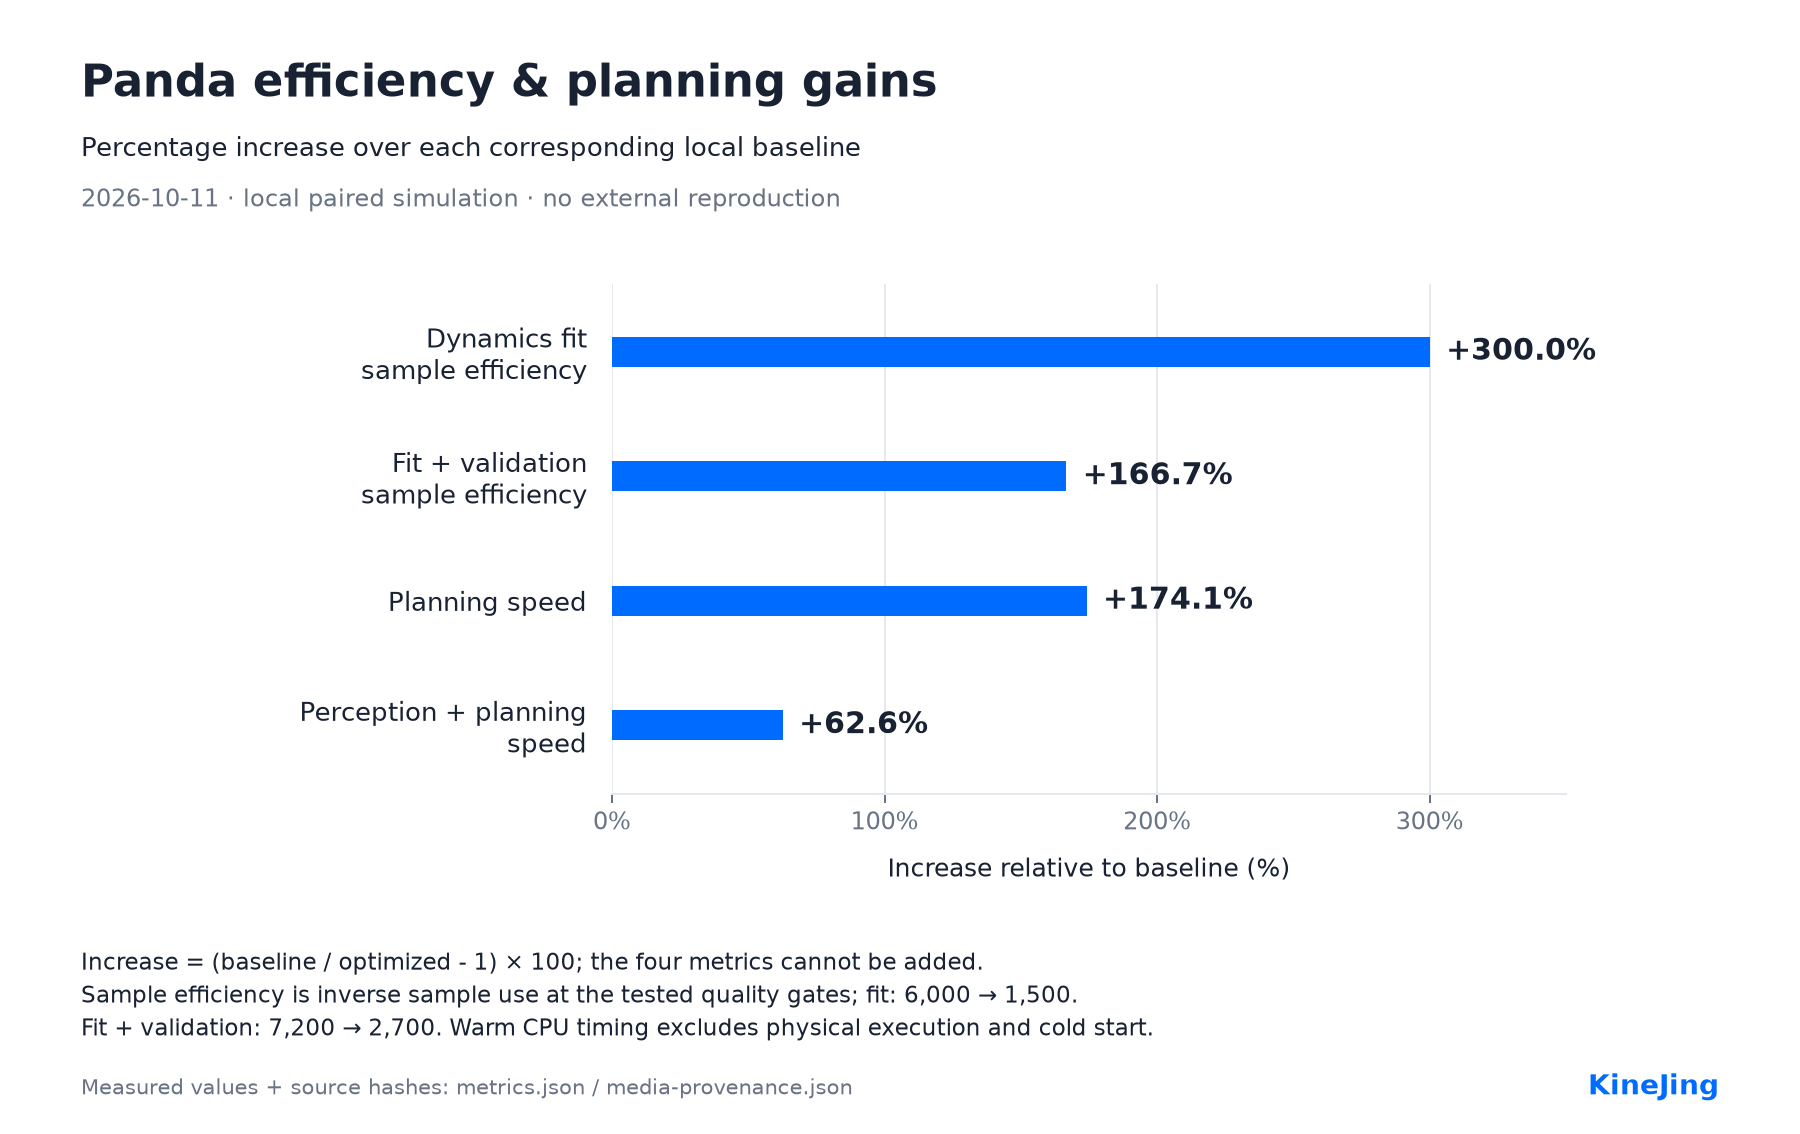
Quality confirmation: the 1,500-fit neural model and the 6,000-fit RBF / neural baselines each succeeded in 80/80 new paired scenes across four conditions. Compiled planning matched 1,782 recorded actions; planner and perception optimizations each matched all steps in 16 fresh paired trajectories, with both implementations at 15/16 and the shared failure retained.
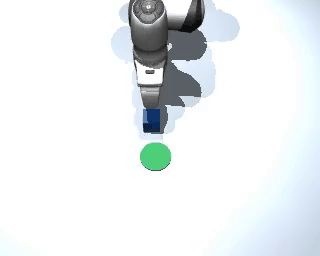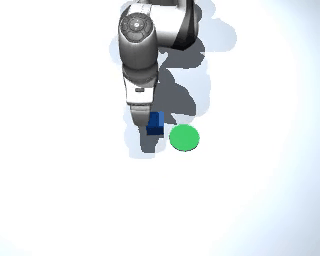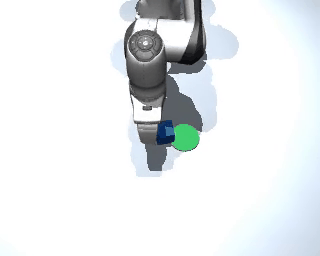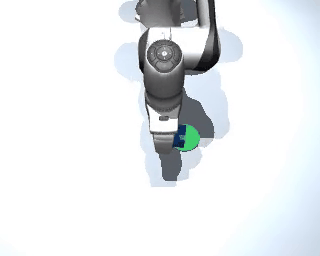
Watch / download the actual simulation video · Success by condition · Full results and measurements

Measurement scope: increase = (baseline / optimized − 1) × 100. Sample efficiency is inverse sample use at the tested quality gates, with a shared 1,200-sample validation set; total research collection already included 6,000 training transitions. Speed uses warm CPU medians on an i9-13900HX with one thread, excluding physics, actuator execution and cold start. These metrics cannot be added. The task uses a known 5 cm cube, simulated RGB-D and a 4,868-parameter state dynamics model; real-robot validation and independent external reproduction remain pending. Rejected short planning increased speed 542.5% but reduced success from 98.75% to 66.25%; its records remain in the audit. The video illustrates the preset first seed.
Robot assets: DeepMind Menagerie, Apache-2.0. Source revision, media checksums and attribution.
The original result files, experiment identities and historical hashes remain unchanged. GitHub organization URLs currently use kineworld; our company brand is KineJing / 勘境.